Open-World Manipulation
Can a robot handle an object it has never seen, with no CAD model?
- Model-free 6D pose and scale
- Novel and fast-moving objects
- Skills from one demonstration
Related: Any6D, Event6D, GraspClutter6D
Robots that handle objects they have never seen, with bodies they have never used, and get better the more they are used.
GROW Lab builds General-purpose Robots for the Open World.
We study how robots perceive, act and keep learning in the real world, from grippers and dexterous hands to humanoids.
Because the real world keeps changing: new objects, new robot bodies, and everything after deployment. We ask one question for each.
Can a robot handle an object it has never seen, with no CAD model?
Related: Any6D, Event6D, GraspClutter6D
Can the same skill run on a new gripper, hand or camera without retraining?
Related: XGrasp, GraspGraphNet
Can a deployed robot keep improving from its own successes and failures?
Related: TTA-COPE, UDA-COPE
↻Repeat, and the robot grows.
Where it lands
Novel objects, clutter, fast motion, new grippers and hands, on real robots.
* equal contribution, † corresponding. Full list on taeyeop.com and Google Scholar.
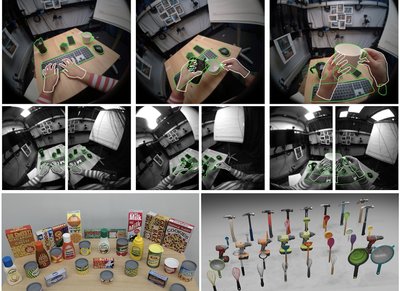
BOP Challenge 2024: Model-free, Model-based Detection, and Pose Estimation of Unseen Rigid Objects
Van Nguyen Nguyen, Stephen Tyree, Andrew Guo, Médéric Fourmy, Anas Gouda, Taeyeop Lee, Sungphill Moon, Hyeontae Son, Lukas Ranftl, Jonathan Tremblay, Eric Brachmann, Bertram Drost, Vincent Lepetit, Carsten Rother, Stan Birchfield, Jiri Matas, Yann Labbé, Martin Sundermeyer, Tomáš Hodaň
CVPR 2025 Workshop on Computer Vision for Mixed Reality (CV4MR)Best paper
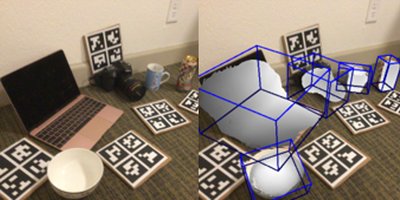
GraspClutter6D: A Large-scale Real-world Dataset for Robust Perception and Grasping in Cluttered Scenes
Seunghyeok Back, Joosoon Lee, Kangmin Kim, Heeseon Rho, Geonhyup Lee, Raeyoung Kang, Sangbeom Lee, Sangjun Noh, Youngjin Lee, Taeyeop Lee, Kyoobin Lee
IEEE Robotics and Automation Letters (RA-L), 2025 · presented at ICRA 2026
Drag4D: Align Your Motion with Text-Driven 3D Scene Generation
Minjun Kang*, Inkyu Shin*, Taeyeop Lee, In So Kweon, Kuk-Jin Yoon
Preprint, 2025
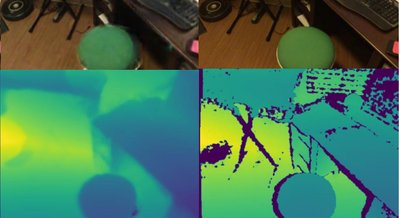
Stable Surface Regularization for Fast Few-Shot NeRF
ByeongIn Joung, Byeong-Uk Lee, Jaesung Choe, Ukcheol Shin, Minjun Kang, Taeyeop Lee, In So Kweon, Kuk-Jin Yoon
International Conference on 3D Vision (3DV), 2024
Principal Investigator · Senior Researcher, AI Robot Institute, KIST · Ph.D., KAIST
Taeyeop is a Senior Researcher at the AI Robot Institute, KIST. He received his Ph.D. and M.S. from KAIST and his B.S. from Kwangwoon University. He has been fortunate to collaborate with NVIDIA Research, Meta and Adobe Research, and is a recipient of the Presidential Award of Korea.
Do world-class robot AI with world-class collaborators.
We work with researchers at NVIDIA, Google, Meta and KAIST, and aim every project at the top venues in robotics and AI. Join us to bring VLA models, robot learning, dexterous hands and humanoids into the real world.
Student recruiting notices (M.S./Ph.D., Jan. & Aug.) · Employment announcements (interns, post-docs)
Institutions we have worked and published with.